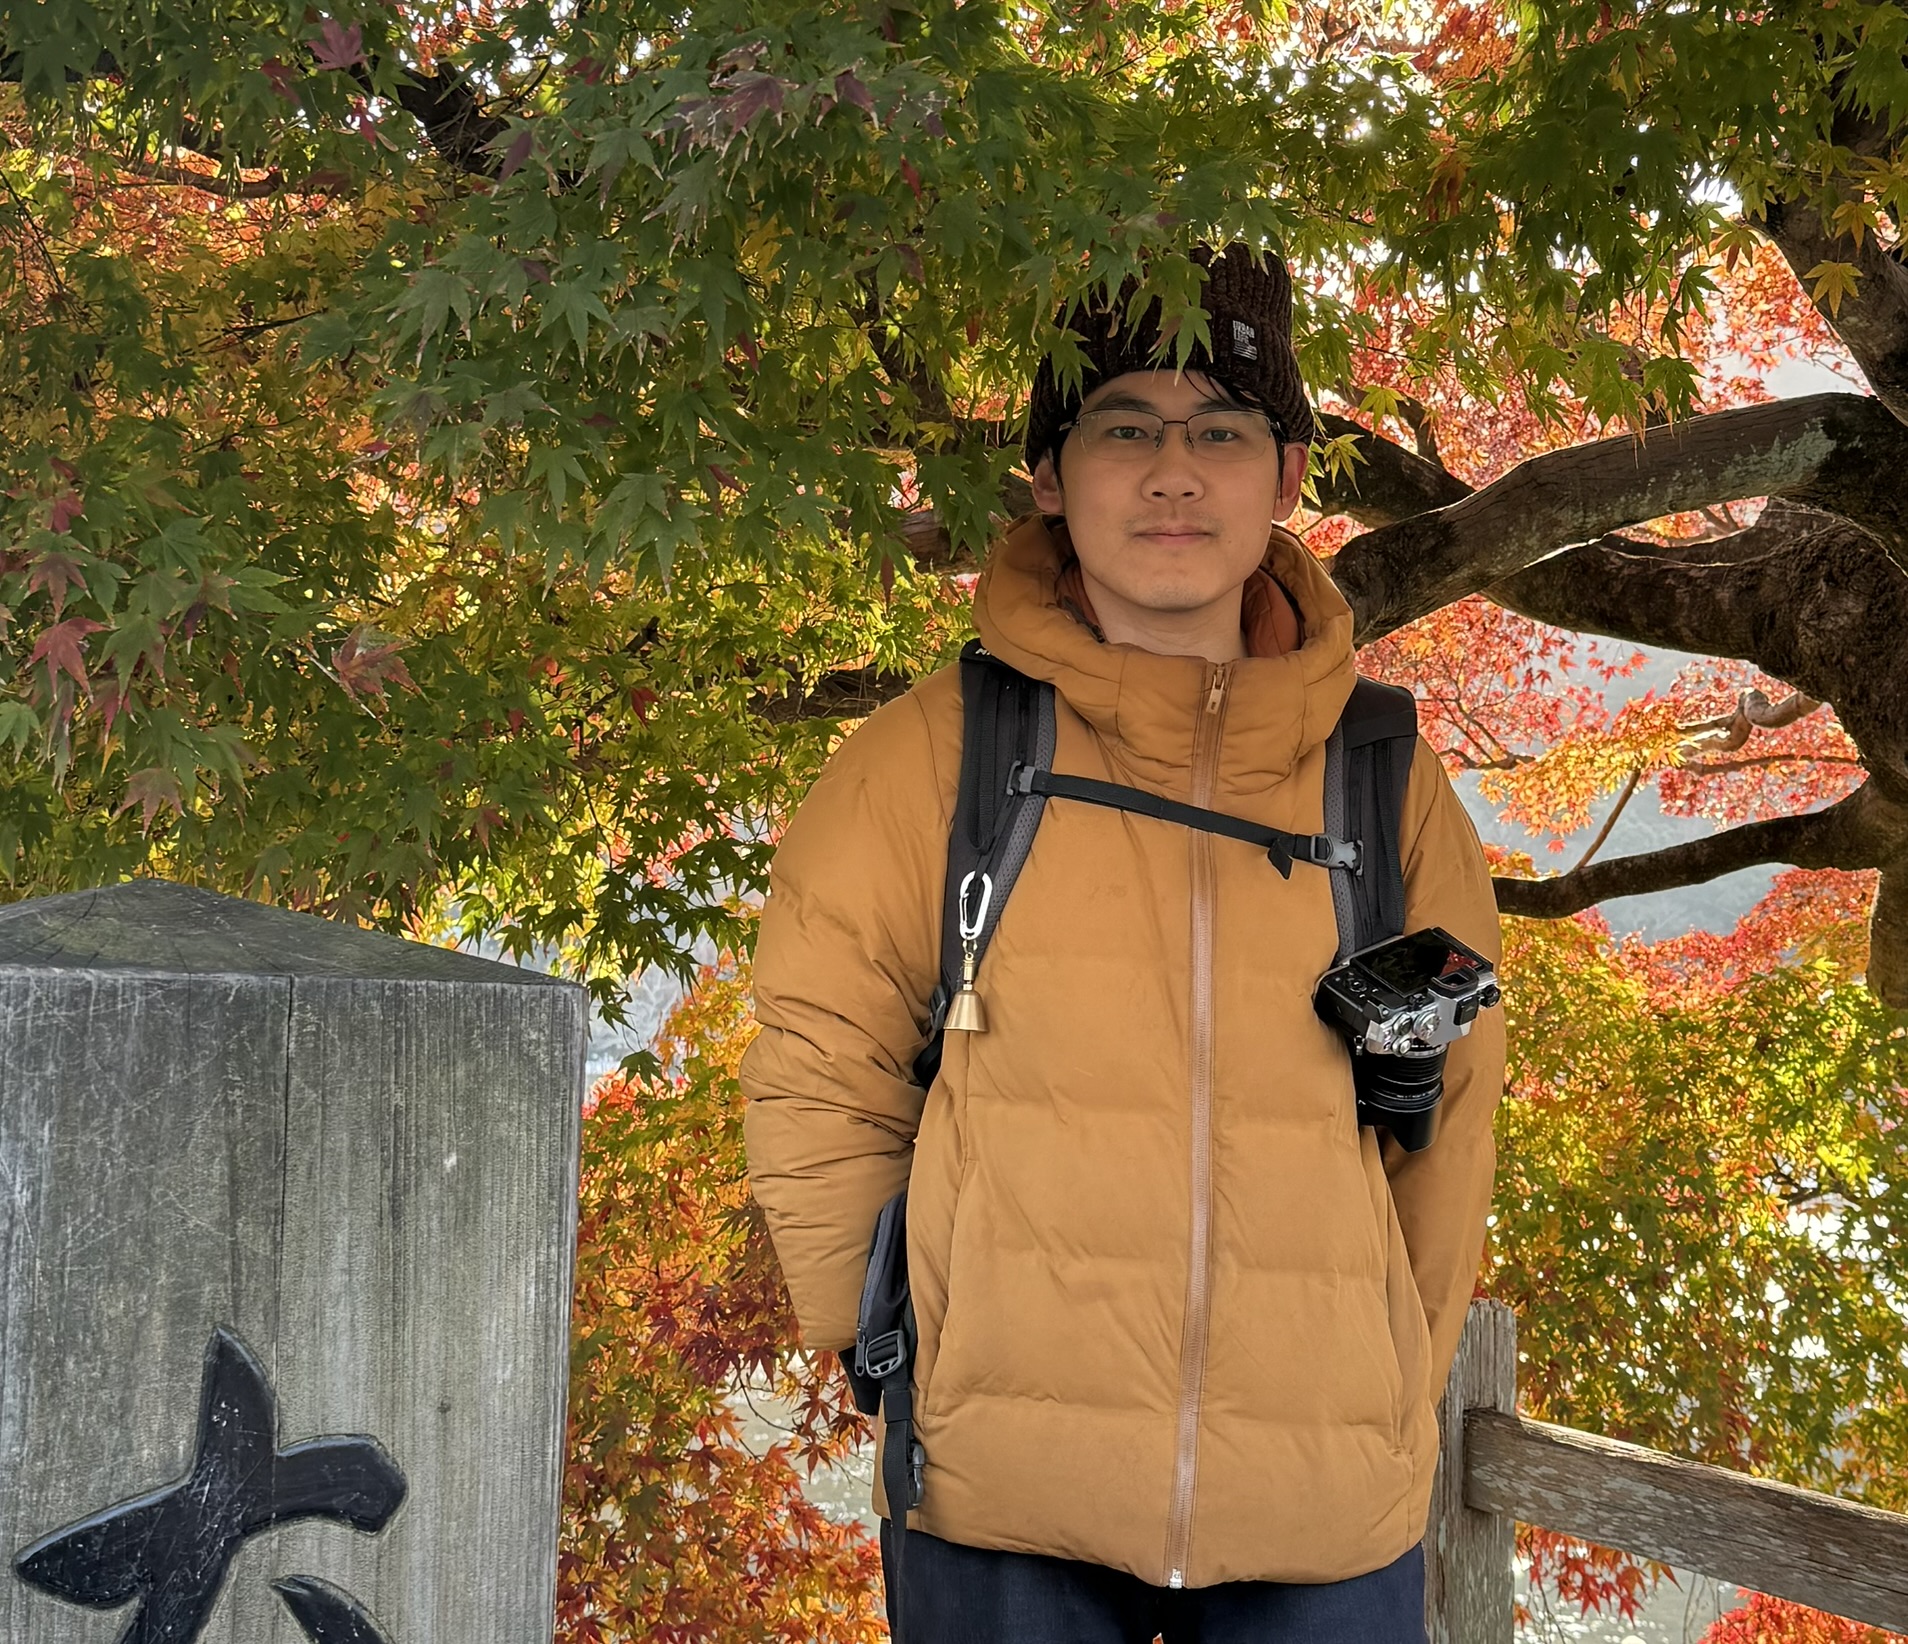
Ziyan Gao - Robotic Manipulation Researcher
About Me
I am a Research Assistant Professor at the Japan Advanced Institute of Science and Technology (JAIST), specializing in robotic manipulation. My research focuses on developing and robust algorithms for solving practical planning problems.
Research Interests
My current research interests include:
- Robot Grasping and Manipulation: Developing methods for robust object grasping in high-clutter and unstructured scenarios
- Vision-based Robotic Control: Using visual feedback to guide robotic manipulation tasks
- Machine Learning for Robotics: Applying deep learning and neural networks to improve robotic perception and decision-making
- Multimodal Learning: Integrating multiple sensory modalities for more effective robot control
I am particularly interested in the intersection of computer vision, machine learning, and robotics, with applications to real-world robotic systems. My work aims to bridge the gap between theoretical advances in AI and practical robotic applications.
Specialized Research Fields
Non-prehensile Manipulation
- Analytical and data-driven analysis of the under-actuated pusher-slider system
Object Physical Parameter Estimation
- Estimation of physical parameters for novel objects based on robot-object interaction
Data-driven Robotic Grasping
- Deep neural network training based on large-scale simulation data for robotic grasping
Robotic Bin Packing
- Heuristic integrated effective online bin packing using deep reinforcement learning
For more information about my research, please explore the Publications, Teaching, Portfolio, and researchmap pages.