Visual Prompt Guided Unified Pushing Policy
Bui, H.*, Gao, Z.*, Hosoda, Y., & Lee, J. (2026). Visual Prompt Guided Unified Pushing Policy. arXiv preprint arXiv:2602.19193. (* Equal contribution, co-corresponding authors)
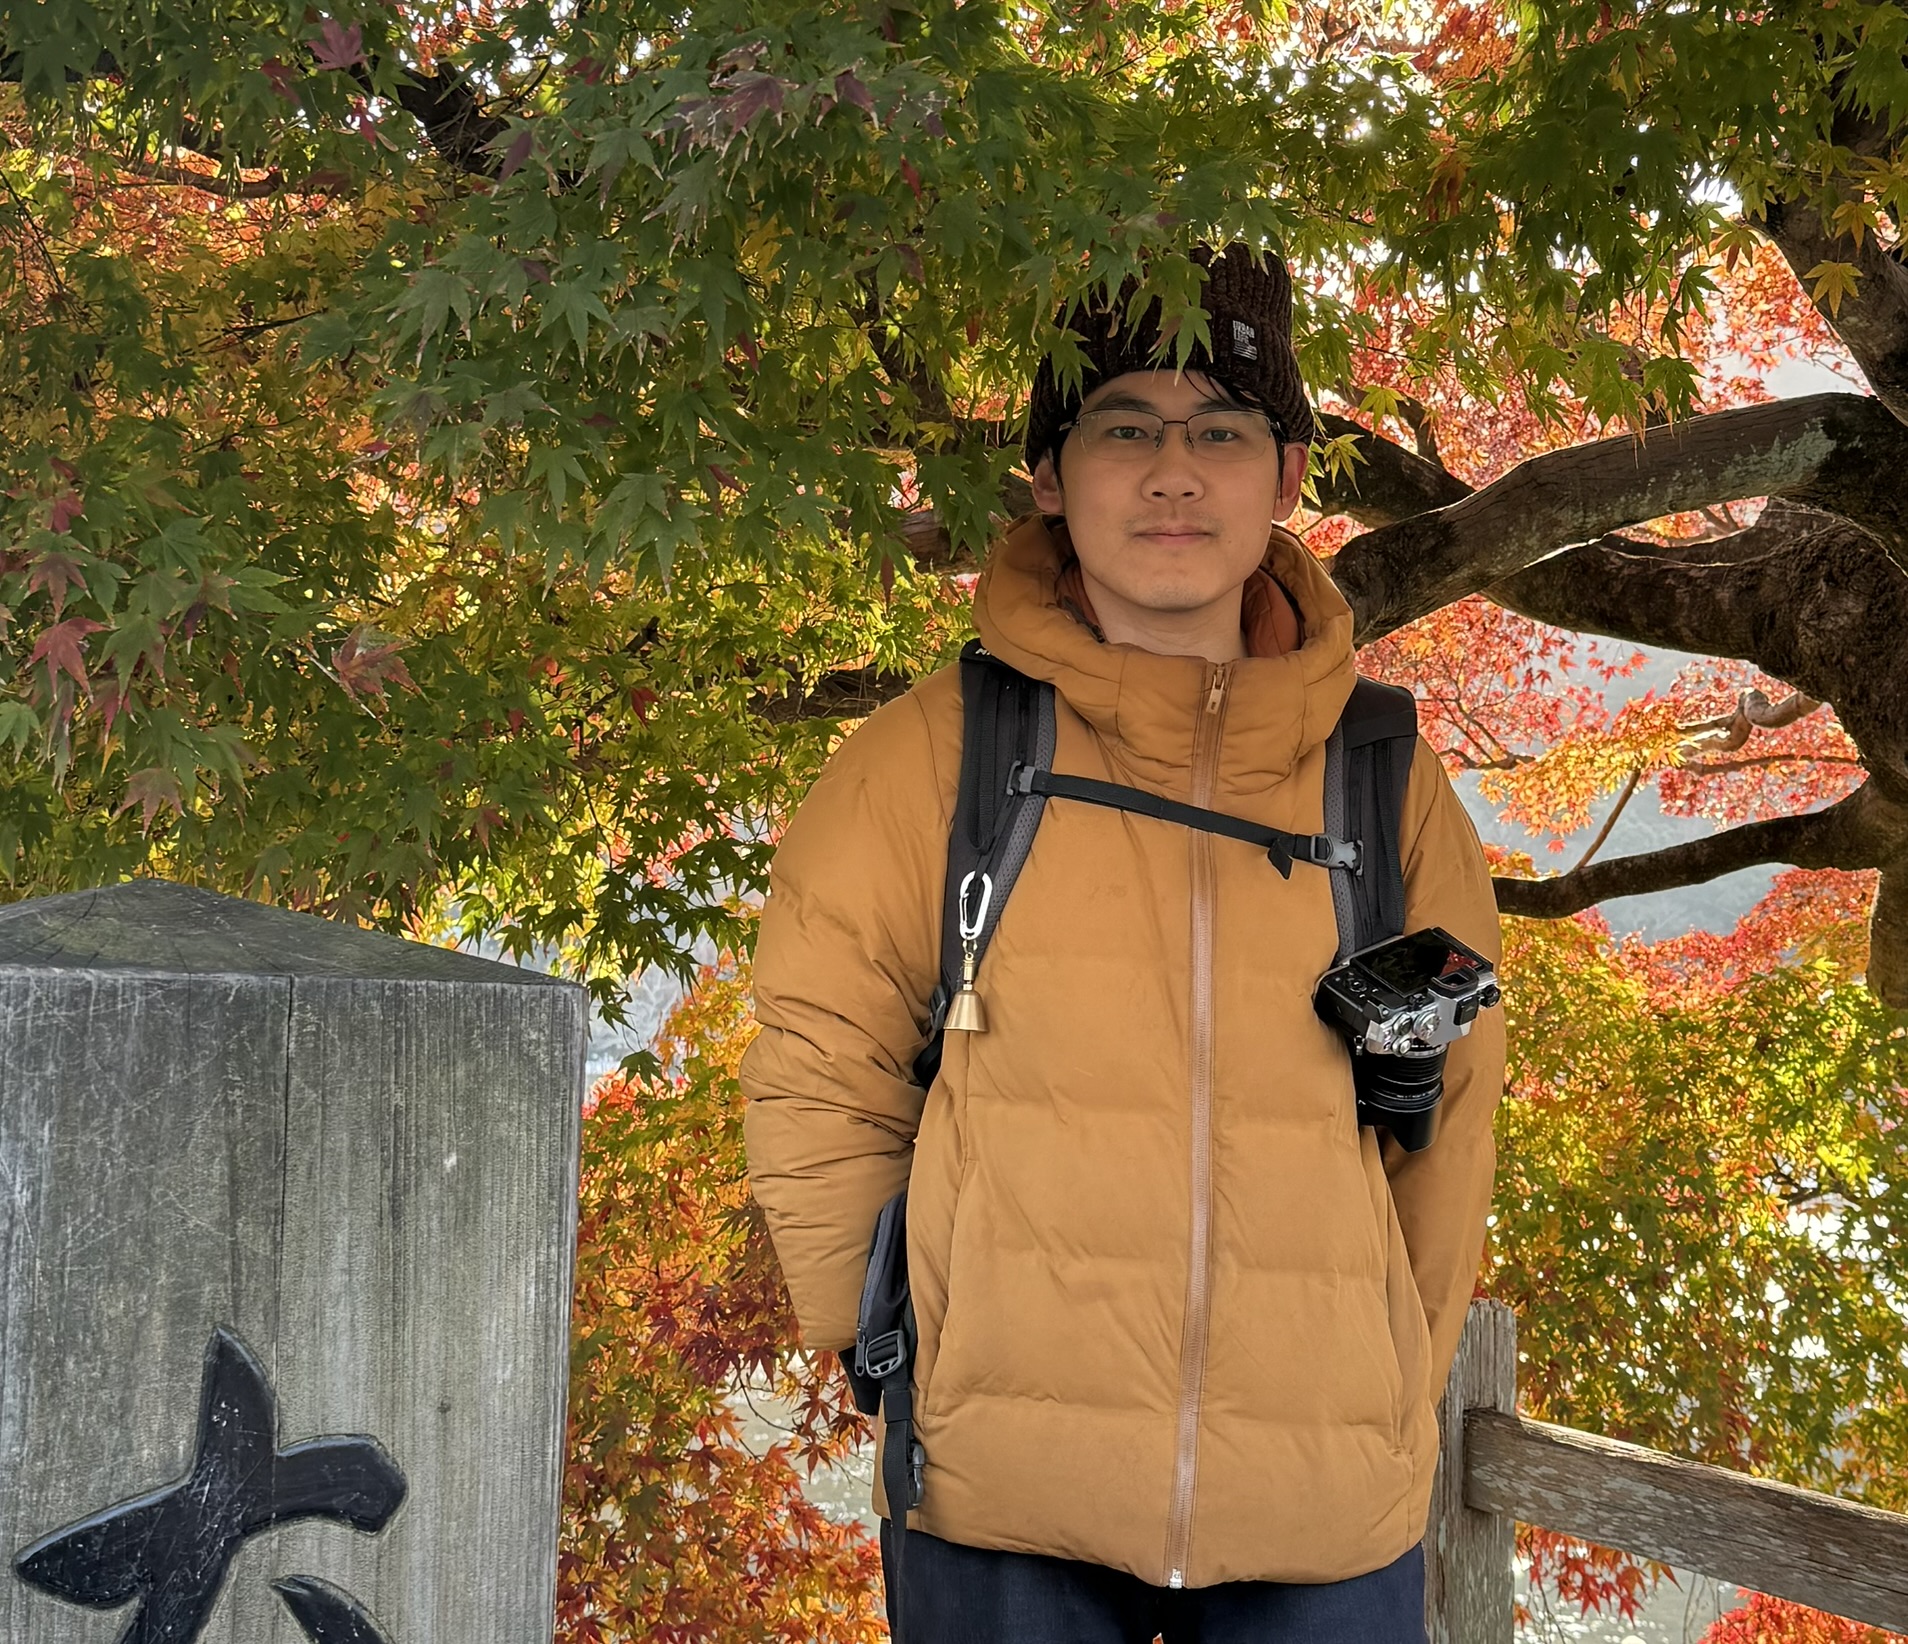
Name: Ziyan Gao
Gender: Male
Nationality: China
Email: gziyan1237@gmail.com
Address: 1-1, Asahidai, Nomi City, Ishikawa, Japan
2012.9 – 2016.6
B.S. in Mechanical Engineering, Qingdao University of Science and Technology, Qingdao city, Shandong, China. (Graduated)
Thesis title: Structural Design and Kinematic Analysis of a Four-Degree-of-Freedom Robotic Arm
2016.10 – 2019.3
M.S. in Information Science, Japan Advanced Institute of Science and Technology, Nomi city, Ishikawa, Japan. (Graduated)
Thesis title: Efficient Robot Grasp Learning by Demonstration
2019.4 – 2022.9
Ph.D. in Information Science, Japan Advanced Institute of Science and Technology, Nomi city, Ishikawa, Japan. (Graduated)
Thesis title: A Few-Shot Learning Approach To Controlled Planar Pushing Of Novel Objects On Unknown Frictional Surfaces
2025/12/1 – present
Research Assistant Professor
School of Information Science, Japan Advanced Institute of Science and Technology
2025/4/1 – 2025/11/30
Senior Researcher
School of Information Science & Engineering, Ritsumeikan University
2022/10/1 – 2025/3/31
Post-Doctoral Researcher
School of Information Science, Japan Advanced Institute of Science and Technology
Non-prehensile Manipulation
Object Physical Parameter Estimation
Data-driven Robotic Grasping
Robotic Bin Packing
Associate Editor
Reviewer
Best Paper Award
The paper entitled “A few-shot learning framework for planar pushing of unknown objects.” won the best paper award from Intelligent Service Robotics (ISR) and was presented at the 20th International Conference on Ubiquitous Robots, New York, USA / June 25 - 28, 2023.
Teaching Assistant (2023 – 2024)
Japan Advanced Institute of Science and Technology (Tokyo Campus)
During the 2023 Term 2-2 and 2024 academic terms, I served as a teaching assistant for a robotics class led by Professor Nak Young Chong. My responsibilities included:
Teaching Philosophy: I emphasize simplifying concepts by avoiding unnecessary complex terminology. For intricate algorithms, I provide well-commented code examples to enhance student comprehension and facilitate learning.
Bui, H.*, Gao, Z.*, Hosoda, Y., & Lee, J. (2026). Visual Prompt Guided Unified Pushing Policy. arXiv preprint arXiv:2602.19193. (* Equal contribution, co-corresponding authors)
Li, C., Gao, Z., & Chong, N. Y. (2025). Shortcut-enhanced Multimodal Backdoor Attack in Vision-guided Robot Grasping. IEEE Transactions on Automation Science and Engineering.
Gao, Z., Wang, L., Kong, Y., & Chong, N. Y. (2025). Online 3D Bin Packing with Fast Stability Validation and Stable Rearrangement Planning. Robotics and Computer-Integrated Manufacturing (Under Review).
Wang, L., Lu, Y., Gao, Z., Li, K., Huang, J., Kong, Y., & Okada, S. (2025). Berp: A blind estimator of room parameters for single-channel noisy speech signals. IEEE Transactions on Audio, Speech and Language Processing.
Liao, K., Elibol, A., Gao, Z., Meng, L., & Chong, N. Y. (2025). Predicting hemodynamic parameters based on arterial blood pressure waveform using self-supervised learning and fine-tuning. Applied Intelligence, 55(7), 481.
Ma, D., Imamura, K., Gao, Z., Wang, X., & Yamane, S. (2025). Hierarchical Motion Field Alignment for Robust Optical Flow Estimation. Sensors, 25(9), 2653.
Gao, Z., Elibol, A., & Chong, N. Y. (2024). On the generality and application of mason's voting theorem to center of mass estimation for pure translational motion. IEEE Transactions on Robotics, 40, 2656-2671.
Gao, Z., Elibol, A., & Chong, N. Y. (2022). Zero moment two edge pushing of novel objects with center of mass estimation. IEEE Transactions on Automation Science and Engineering, 20(3), 1487-1499.
Gao, Z., Elibol, A., & Chong, N. Y. (2022). A few-shot learning framework for planar pushing of unknown objects. Intelligent Service Robotics, 15(3), 335-350.
Programming Languages & Tools
Research Methods
Languages