UNO Push: Unified Nonprehensile Object Pushing
Published:
Overview
This is an implementation of the work published in IEEE Xplore (Document ID: 10802843): UNO Push: Unified Nonprehensile Object Pushing via Non-Parametric Estimation and Model Predictive Control
Note: This is my implementation of the UNO Push algorithm. I did not author the original work; this is a reproduction/implementation of the published research.
This implementation demonstrates unified nonprehensile object pushing techniques using non-parametric estimation and model predictive control for robotic manipulation. The system enables the robot to manipulate objects through pushing actions.
Demo
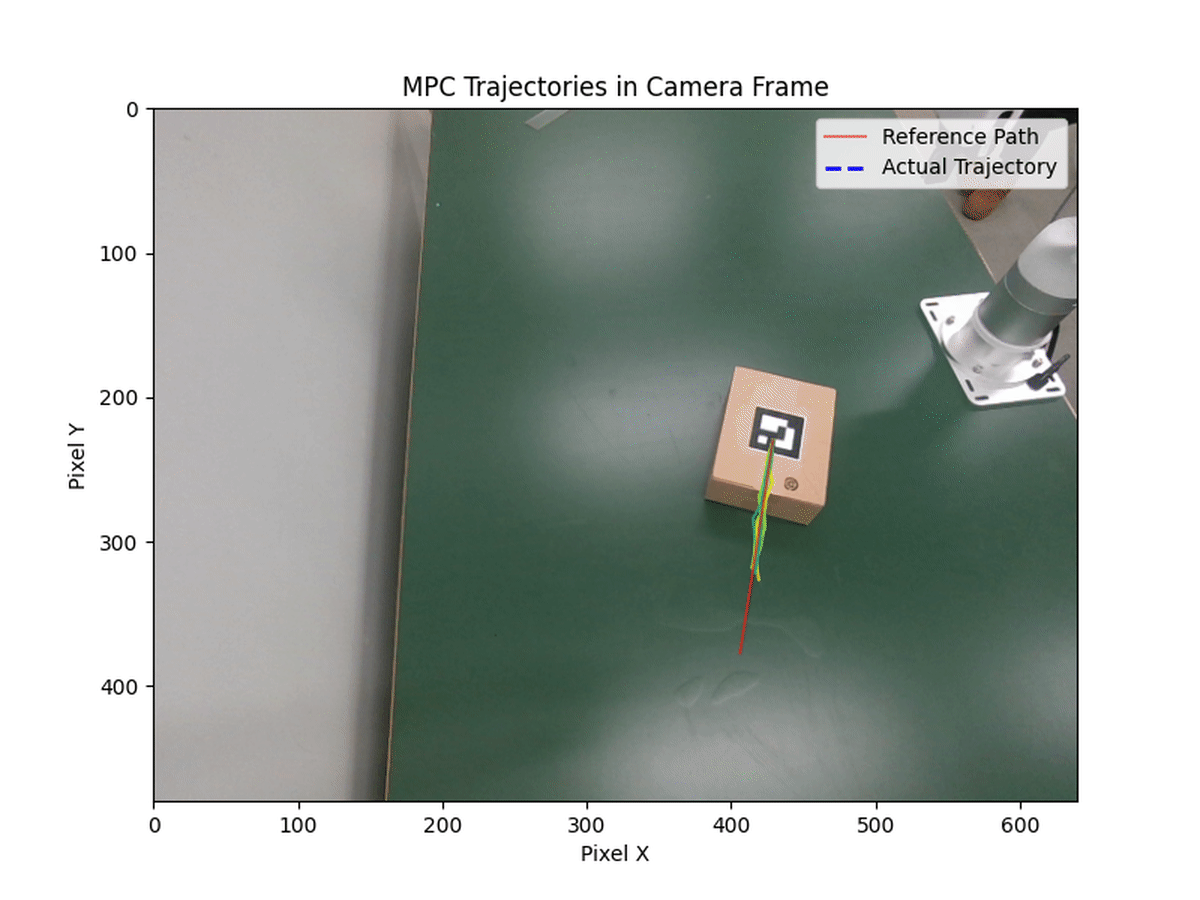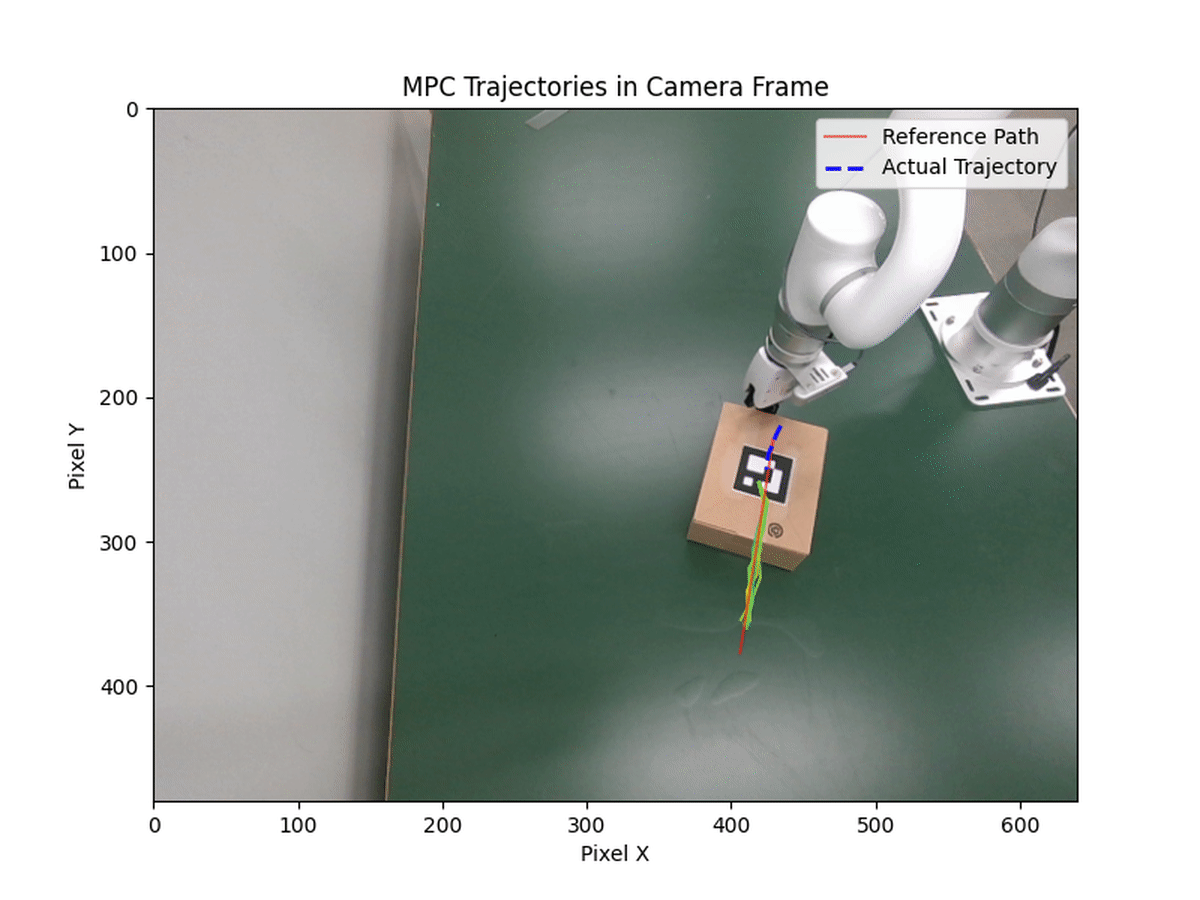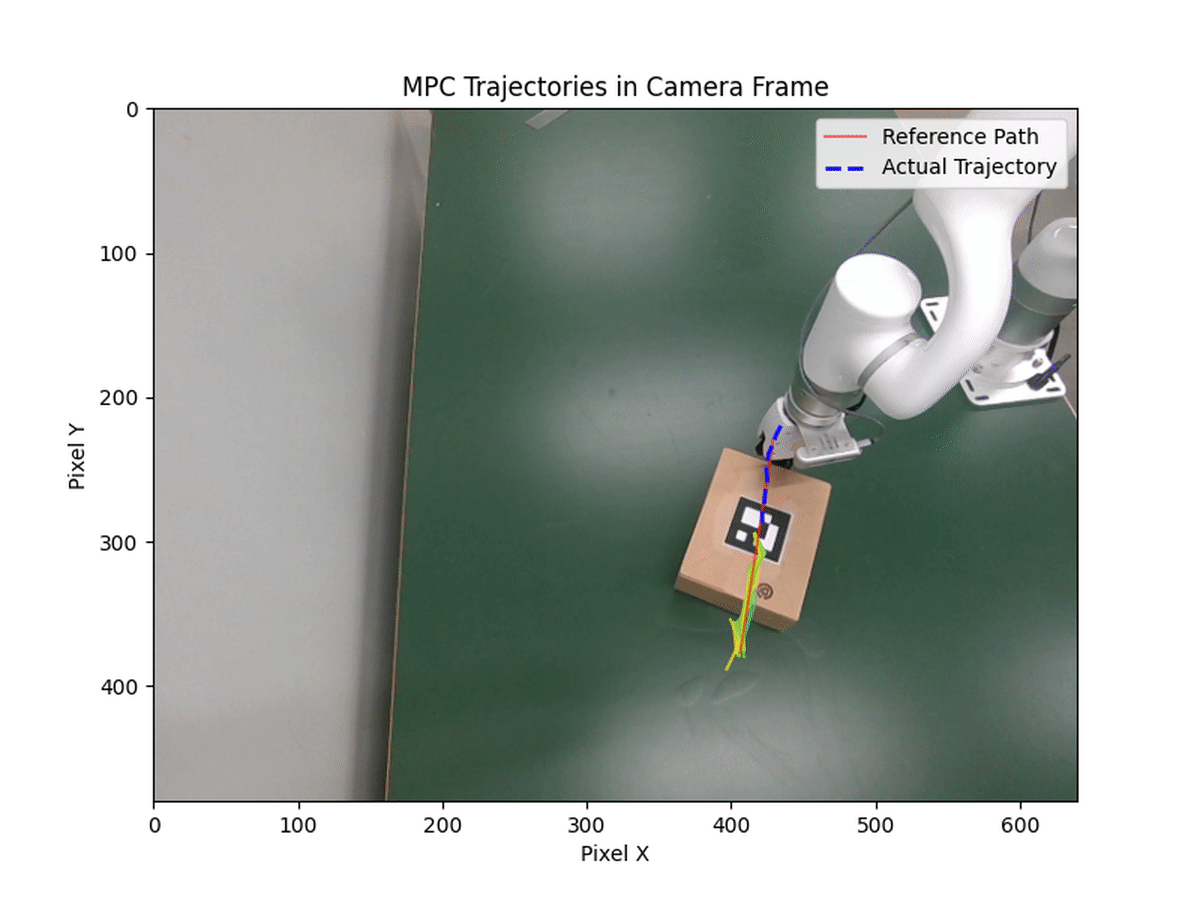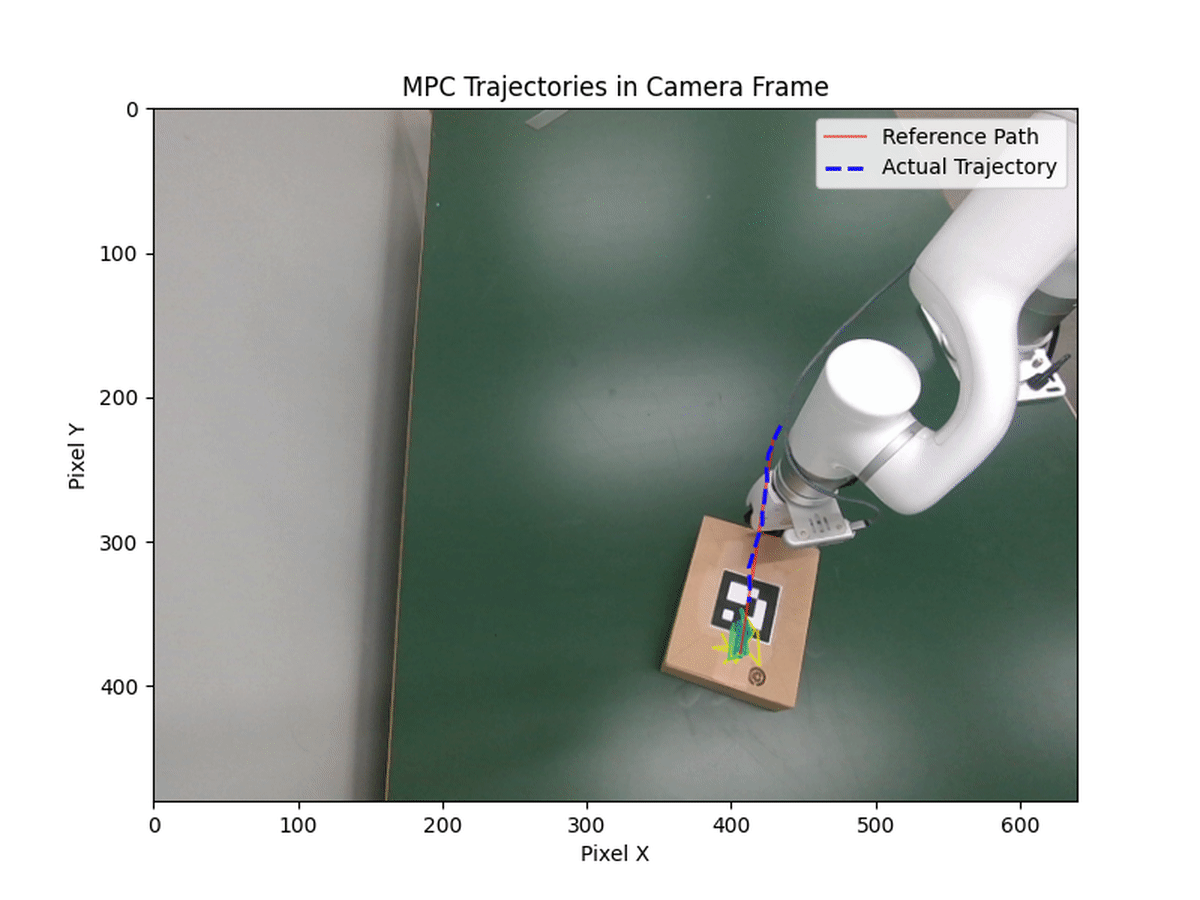
The demo illustrates the system’s ability to manipulate objects through nonprehensile pushing control using MPC-based planning and execution.