UNO Push: Unified Nonprehensile Object Pushing
Published:
Implementation of UNO Push - Unified Nonprehensile Object Pushing via Non-Parametric Estimation and Model Predictive Control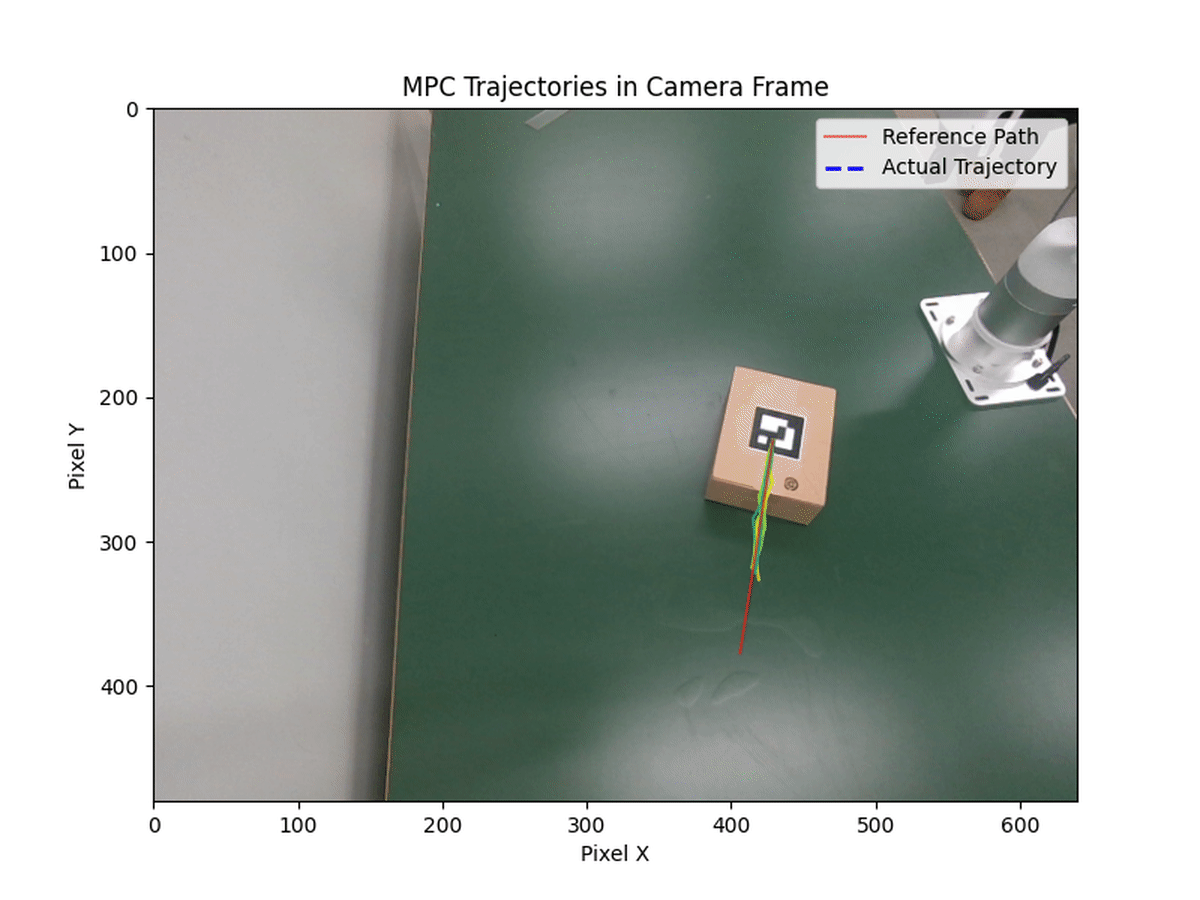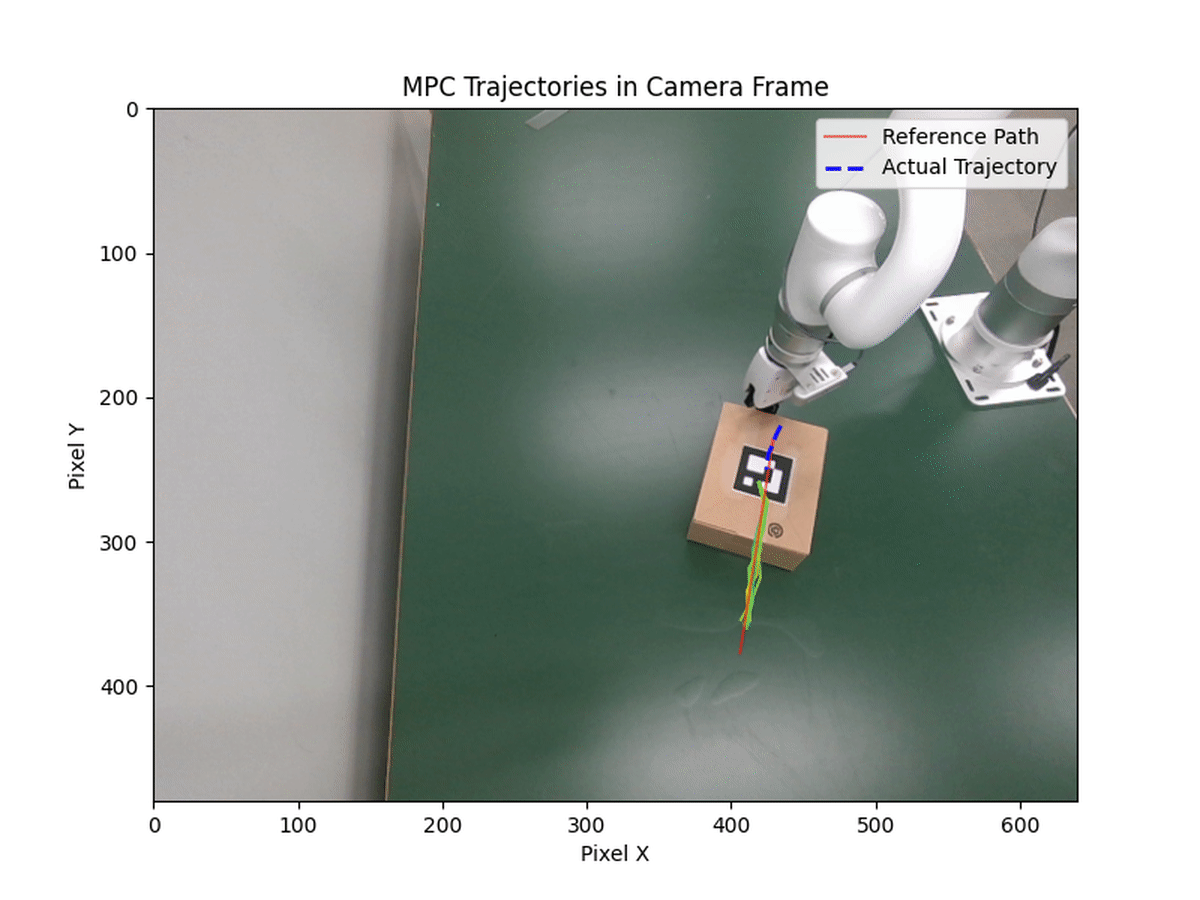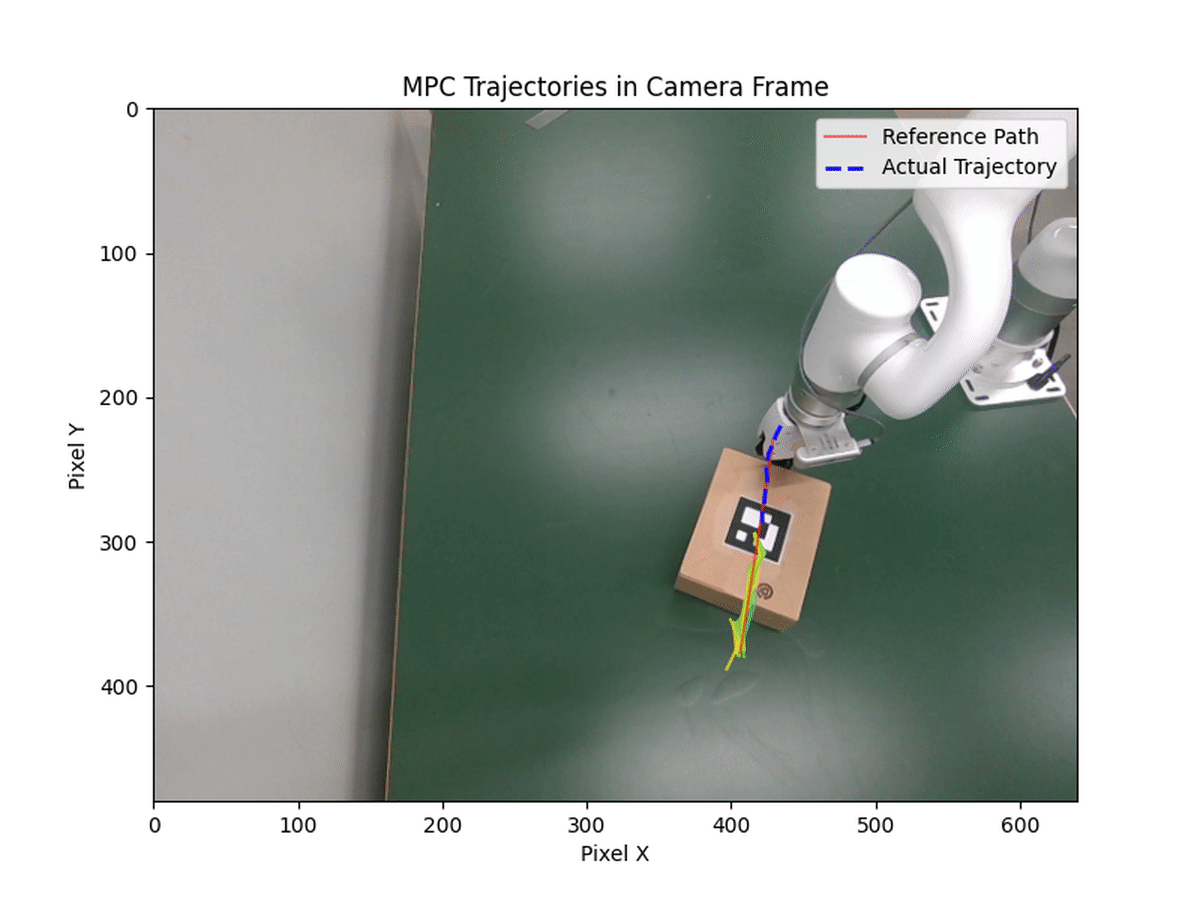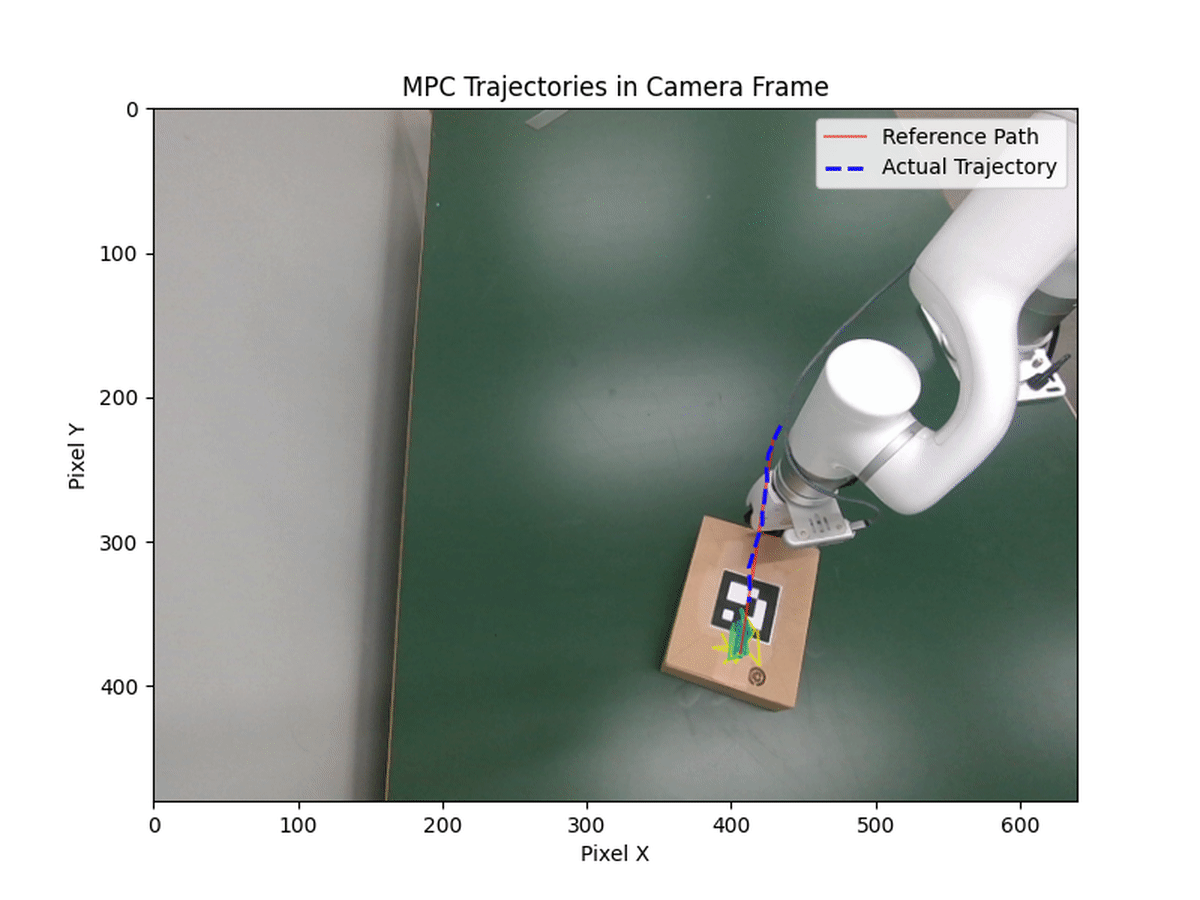
Published:
Implementation of UNO Push - Unified Nonprehensile Object Pushing via Non-Parametric Estimation and Model Predictive Control
Short description of portfolio item number 1
Short description of portfolio item number 2
Published in Intelligent Service Robotics, 2022
Presents a few-shot learning framework for robot planar pushing with a new large dataset and novel representation for pushing primitives, including computation efficient planning method.
Recommended citation: Gao, Z., Elibol, A., & Chong, N. Y. (2022). A few-shot learning framework for planar pushing of unknown objects. Intelligent Service Robotics, 15(3), 335-350.
Download Paper
Published in IEEE Transactions on Automation Science and Engineering, 2022
Pushing is one of the fundamental nonprehensile manipulation skills. This work estimates the center of mass of an object and proposes the Zero Moment Two Edge Pushing method to translate a novel object without rotation to a goal pose.
Recommended citation: Gao, Z., Elibol, A., & Chong, N. Y. (2022). Zero moment two edge pushing of novel objects with center of mass estimation. IEEE Transactions on Automation Science and Engineering, 20(3), 1487-1499.
Download Paper
Published in IEEE Transactions on Robotics, 2024
Extends Mason Voting Theorem to object center of mass estimation in the absence of accurate information on friction and object shape using a position-controlled robot arm and vision sensor.
Recommended citation: Gao, Z., Elibol, A., & Chong, N. Y. (2024). On the generality and application of mason's voting theorem to center of mass estimation for pure translational motion. IEEE Transactions on Robotics, 40, 2656-2671.
Download Paper
Published in Sensors, 2025
Proposes a learning-based model with Hierarchical Motion Field Alignment module and Correlation Self-Attention module for improved optical flow estimation, particularly for small and fast-moving objects.
Recommended citation: Ma, D., Imamura, K., Gao, Z., Wang, X., & Yamane, S. (2025). Hierarchical Motion Field Alignment for Robust Optical Flow Estimation. Sensors, 25(9), 2653.
Download Paper
Published in Applied Intelligence, 2025
Proposes SSHemo, a self-supervised generative learning model for hemodynamic parameter prediction from arterial blood pressure waveforms, addressing data scarcity through self-supervised learning.
Recommended citation: Liao, K., Elibol, A., Gao, Z., Meng, L., & Chong, N. Y. (2025). Predicting hemodynamic parameters based on arterial blood pressure waveform using self-supervised learning and fine-tuning. Applied Intelligence, 55(7), 481.
Download Paper
Published in IEEE Transactions on Audio, Speech and Language Processing, 2025
Proposes BERP, a universal approach to blindly estimate room acoustical parameters, room geometrical parameters, and occupancy levels from noisy single-channel speech signals using attention mechanisms.
Recommended citation: Wang, L., Lu, Y., Gao, Z., Li, K., Huang, J., Kong, Y., & Okada, S. (2025). Berp: A blind estimator of room parameters for single-channel noisy speech signals. IEEE Transactions on Audio, Speech and Language Processing.
Download Paper
Published in Robotics and Computer-Integrated Manufacturing (Under Review - Second Round), 2025
Proposes a novel framework that integrates packing policy with structural stability validation and heuristic planning, introducing Load Bearable Convex Polygon for computationally efficient stable loading positions.
Recommended citation: Gao, Z., Wang, L., Kong, Y., & Chong, N. Y. (2025). Online 3D Bin Packing with Fast Stability Validation and Stable Rearrangement Planning. Robotics and Computer-Integrated Manufacturing (Under Review).
Download Paper
Published in IEEE Transactions on Automation Science and Engineering, 2025
Proposes SEMBA, a novel backdoor attack method on multimodal vision-guided robot grasping in high-clutter scenarios, using Multimodal Shortcut Searching Algorithm and Multimodal Trigger Generation.
Recommended citation: Li, C., Gao, Z., & Chong, N. Y. (2025). Shortcut-enhanced Multimodal Backdoor Attack in Vision-guided Robot Grasping. IEEE Transactions on Automation Science and Engineering.
Download Paper
Published in arXiv preprint, 2026
Proposes a unified pushing policy that incorporates a lightweight prompting mechanism into a flow matching policy to guide reactive, multimodal pushing actions for object rearrangement and table-cleaning tasks.
Recommended citation: Bui, H.*, Gao, Z.*, Hosoda, Y., & Lee, J. (2026). Visual Prompt Guided Unified Pushing Policy. arXiv preprint arXiv:2602.19193. (* Equal contribution, co-corresponding authors)
Download Paper
Published:
This is a description of your talk, which is a markdown file that can be all markdown-ified like any other post. Yay markdown!
Published:
This is a description of your conference proceedings talk, note the different field in type. You can put anything in this field.
Tutorial & Workshop, Japan Advanced Institute of Science and Technology (JAIST), 2024